Guliwa/Projects
05 live builds
Build 01July 2026Field tested

Galaxea A1Z Vision-Guided Interaction Arm

A vision-to-motion prototype built around a six-axis Galaxea A1Z arm and gripper. I received independent access to the hardware for only the final 12 hours, then brought up the control stack, recorded a live demonstration, and replayed a safety-checked trajectory on the real robot.
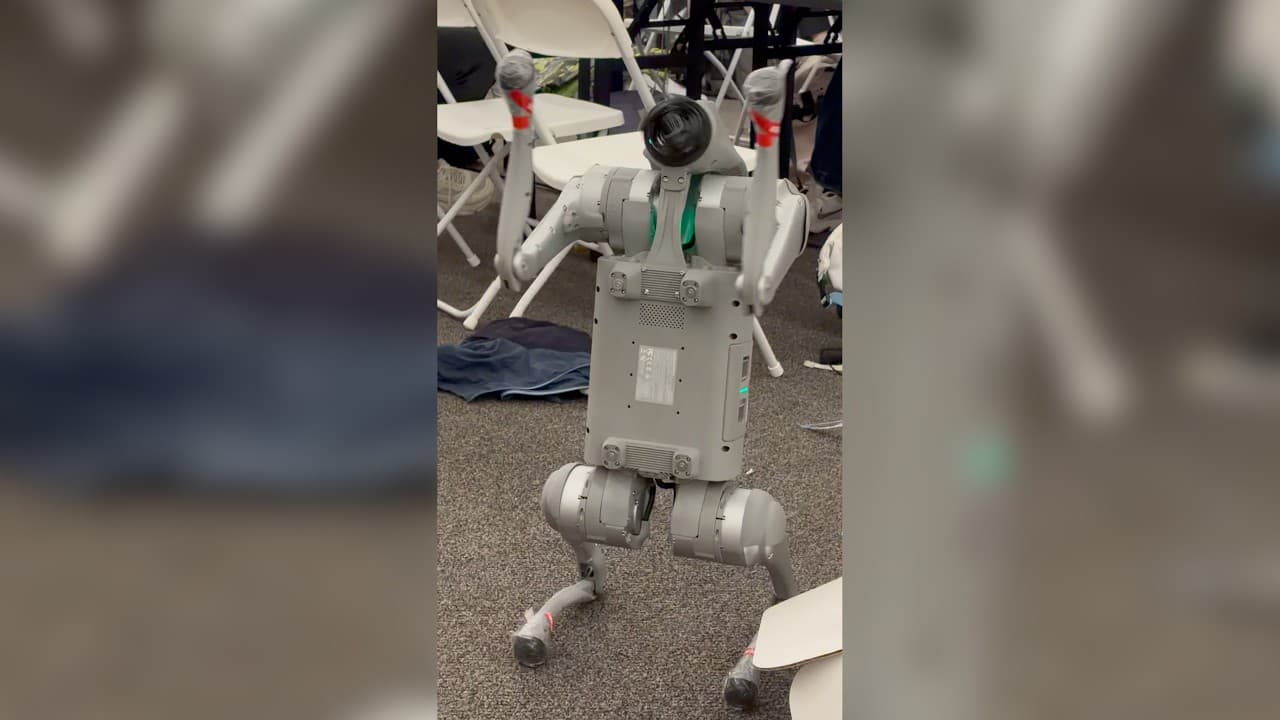
A physical AI event video frame showing a robot demonstration.
Related video

Related field video · physical AI day · 00:47

independent hardware access
12 h
measured demo samples
768
validated replay points
1,431
safety tests passed
14

Five-Day Robotics Hackathon

On-site hardware sprint

Solo subproject

  1. 01Assembled the A1Z from scratch and connected the wrist camera, gs_usb / CAN, and the DimOS 100 Hz ControlCoordinator before delivering the live demo, dataset capture, and trajectory replay.
  2. 02Converted 768 measured samples from a 12.81-second demonstration into a validated 1,431-point, 14.97-second real-robot replay after command and joint-limit checks. The demo completed gripper opening and closing, trajectory hold, and a controlled exit.
  3. 03Evaluated ChArUco / ArUco, Metric3D, and VLA approaches, then shipped the interaction prototype with MediaPipe hand landmarks and an overhead camera. I also completed wrist-camera calibration, four-marker PnP localization, and strict IK execution gates.
  4. 04Wrapped the brake-free arm in fail-closed controls: dry-run by default, process interlocks, physical confirmation, position / velocity / jump limits, and a soft stop before de-energizing. Fourteen dedicated software tests passed.
  • Galaxea A1Z
  • DimOS
  • MediaPipe
  • CAN
  • ChArUco
  • PnP
  • Strict IK
  • Trajectory replay
Build 02July 4–5, 2026Prototype complete

ESPIO Investment Universe

An investment-trading agent interface that turns a live news wire into a navigable asset universe, then runs an automated research loop across hypotheses, vectorized backtests, training selection, and out-of-sample reports.

ESPIO investment universe with a news wire, sector graph, and AI research interface.

Investment universe · news, sectors, and signal topology

ESPIO auto-research screen showing trial results, a selected strategy, and an equity curve.

Auto research · train selection and holdout evaluation

Flow AI investment trading agent hackathon venue with Bobby AI and RockFlow branding.

Flow AI · July 4–5 · Creator @ epark

research trials
65,292
holdout Sharpe
2.19
symbols explored
37
hackathon build
2 days

Flow AI Investment Trading Agent Hackathon

Creator @ epark

Agent system build

  1. 01Mapped news, sectors, supply-chain relationships, and model signals into a visual investment universe designed for human review rather than blind execution.
  2. 02Built an auto-research surface that generated more than 65,000 trials, selected strategies on training data, and kept the final holdout set separate for out-of-sample evaluation.
  • Trading agents
  • Backtesting
  • OOS evaluation
  • Graph UI
  • News signals
  • Bobby AI
  • RockFlow
Build 03June 2026Showcase selected

StockWin

A market intelligence project selected for the UCWS Singapore Hackathon 2026 online showcase. StockWin was listed among the coding-track projects presented on June 8 at 7 PM SGT.

UCWS Singapore Hackathon selected-projects poster listing StockWin by Liwa Gu.

UCWS 2026 · selected projects presentation

project status
Selected
showcase date
Jun 8
Singapore time
7 PM
presentation track
Online

UCWS Singapore Hackathon 2026

Selected Projects Online Presentation

Selected project

  1. 01Built the project around an inspectable market-research workflow, with evidence and system state visible to the person making the final decision.
  2. 02Selected for the Singapore showcase alongside the event’s coding-track projects and presented through the online demo path.
  • Market intelligence
  • Research workflow
  • Agent systems
  • Singapore
  • Online demo
Build 042026Playable build

Paper Desk

A one-person investment-bank simulator built as a compact strategy game. Players allocate $100,000 of paper capital across five assets, read competing AI briefings, and try to beat SPY over five market days.

Paper Desk game interface with asset allocation controls, AI briefings, and a desk score.

Final desk · allocation, briefings, and benchmark score

paper capital
$100k
market days
5
allocatable assets
5
benchmark
SPY

Hong Kong Mini Game Hackathon

Regent Hong Kong Hotel

Solo game build

  1. 01Turned portfolio construction into a five-round game with allocation controls, daily market narratives, drawdown tracking, alpha, and a final desk score.
  2. 02Kept the experience paper-only and broker-free while making benchmark discipline visible at every decision point.
  • Mini game
  • Portfolio allocation
  • AI briefings
  • Benchmark scoring
  • Paper trading
Build 052026Live demo

Scout Dog Walk

A supervised web command console for a Scout Mini mobile robot. The build connected a browser interface to ROS2 motion commands so an operator could run routes, pause, resume, and trigger an emergency stop.

Scout Dog Walk route demo showing a supervised mobile robot path.

Supervised route · browser command console

motion layer
ROS2
chassis control
CAN
operator console
Web
safety action
E-stop

Shenzhen Women's Hardware Hackathon

Shenzhen

Robotics prototype

  1. 01Connected ROSLIB.js and rosbridge to ROS2 /cmd_vel, with CAN control underneath the robot chassis.
  2. 02Designed the interface around explicit operator supervision: visible route state, pause / resume, and an immediate emergency-stop path.
  • Scout Mini
  • ROS2
  • rosbridge
  • ROSLIB.js
  • CAN
  • Supervised autonomy